mouse-joystick-pcb
Single-axis mouse joystick: RP2040 with GPIO isolation, one TMC5130A, torque bridge, brake current sink, analog angle output, InstrumentPort-Digital-50 taps, 36 V protected input with 12 V and 5 V regulators; v1.0 as built.
The assembled board with its design blocks numbered. On the site the picture is a model that turns, or the top render where WebGL is absent, and each number is a link to the block's page: its schematic, parts, ports and placement guidance. Read on the forge, the picture is the plain top render and the table below is the key.
The numbers are links; in a browser with WebGL this picture is a model that turns.
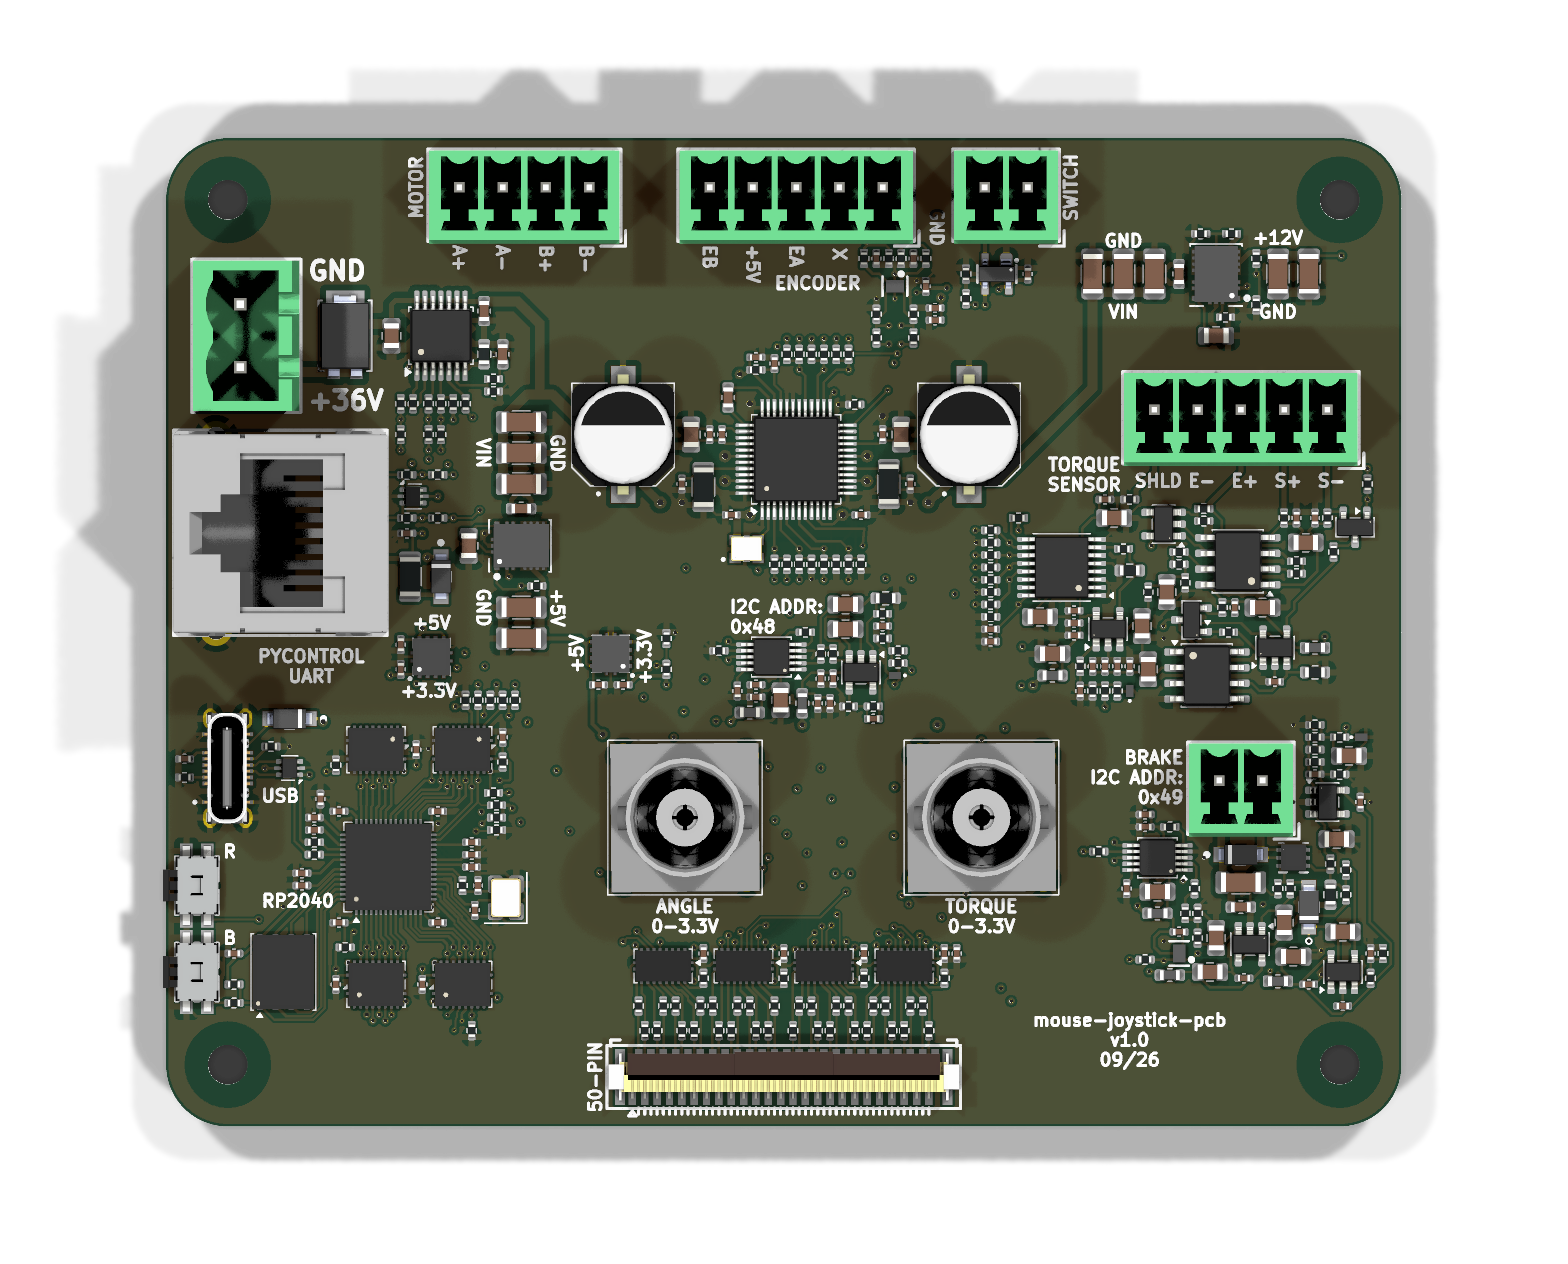
| # | Block instance | Library block | On sheet | Side | Parts |
|---|---|---|---|---|---|
| 1 | hv_input_36V_terminal_2pos_5p08_protected_vertical |
orb_weaver_private:hv_input_36V_terminal_2pos_5p08_protected_vertical |
/ |
top | 18 |
| 2 | quadrature_encoder_input_5v_sn74lvc2g17 |
orb_weaver_private:quadrature_encoder_input_5v_sn74lvc2g17 |
/motor_encoder_switch |
top | 14 |
| 3 | limit_switch_debounced_input_vertical |
orb_weaver_private:limit_switch_debounced_input_vertical |
/motor_encoder_switch |
top | 5 |
| 4 | hv_to_12v_tpsm365r6 |
orb_weaver_tpsm365r6_adjustable:tpsm365r6_adjustable_12v |
/brake_torque_sensor |
top | 13 |
| 5 | pycontrol_behavior_port_rj45_boundary_vertical |
orb_weaver_private:pycontrol_behavior_port_rj45_boundary_vertical |
/ |
top | 9 |
| 6 | hv_to_5v_tpsm365r6 |
orb_weaver_tpsm365r6_fixed:tpsm365r6_fixed_5v |
/ |
top | 9 |
| 7 | tmc5130 |
orb_weaver_tmc5130:tmc5130_spi_r150 |
/motor_encoder_switch |
top | 27 |
| 8 | torque_bridge_0_3v3_ina821 |
orb_weaver_private:torque_bridge_0_3v3_ina821 |
/brake_torque_sensor |
top | 63 |
| 9 | rp2040_with_gpio_isolation_sn74cb3q3245 |
orb_weaver_private:rp2040_with_gpio_isolation_sn74cb3q3245 |
/mcu |
top | 35 |
| 10 | usb2_vertical |
orb_weaver_private:usb2_vertical |
/ |
top | 6 |
| 11 | 5v_to_3v3_tps73733_1 |
orb_weaver_private:5v_to_3v3_tps73733 |
/mcu |
top | 3 |
| 12 | 5v_to_3v3_tps73733_2 |
orb_weaver_private:5v_to_3v3_tps73733 |
/ |
top | 3 |
| 13 | analog_output_0_3v3_dac80501 |
orb_weaver_private:analog_output_0_3v3_dac80501 |
/motor_encoder_switch |
top | 28 |
| 14 | brake_current_sink_0_49ma_dac80501 |
orb_weaver_private:brake_current_sink_0_49ma_dac80501 |
/brake_torque_sensor |
top | 54 |
| 15 | instrument_port_digital_50_dut_ffc_boundary_vertical |
orb_weaver_private:instrument_port_digital_50_dut_ffc_boundary_vertical |
/instrument_port |
top | 46 |
The numbers run left to right, top to bottom over the top view. The model is
3d/mouse-joystick-pcb.glb (metres, Y up, the board's x and y along X and Z); the drawing
3d/top.svg is 3d/top.png at
12.38 px/mm with one rectangle per block, the union of its footprints' courtyards; both and the
footprints of each block are recorded in 3d/hotspots.json.
Each block's page shows the render clipped around its rectangle.

Where to go
- Generated documentation: the renders, every document, the bill of materials and the enclosure reference.
- Design blocks: one page per placed block, with its schematic, parts, ports and place on the board.
- Subsystems from their recipes, and the MCU pin allocation.
- The navigation lists the board's own pages.