Boards
The rig's two circuit boards. Each has its own repository with the schematic,
the layout, the fabrication package, the generated documentation and the
bring-up record; this page is the door to them. The pictures are the board
repositories' own renders at the tagged revision, v1.0 for both.
Joystick controller board
One per station: RP2040, TMC5130A driver, brake current sink, torque bridge, angle and torque analog outputs, pyControl UART on an RJ-45. Placement in the renders follows the 2026-09-21 placement study and is not a fixture.
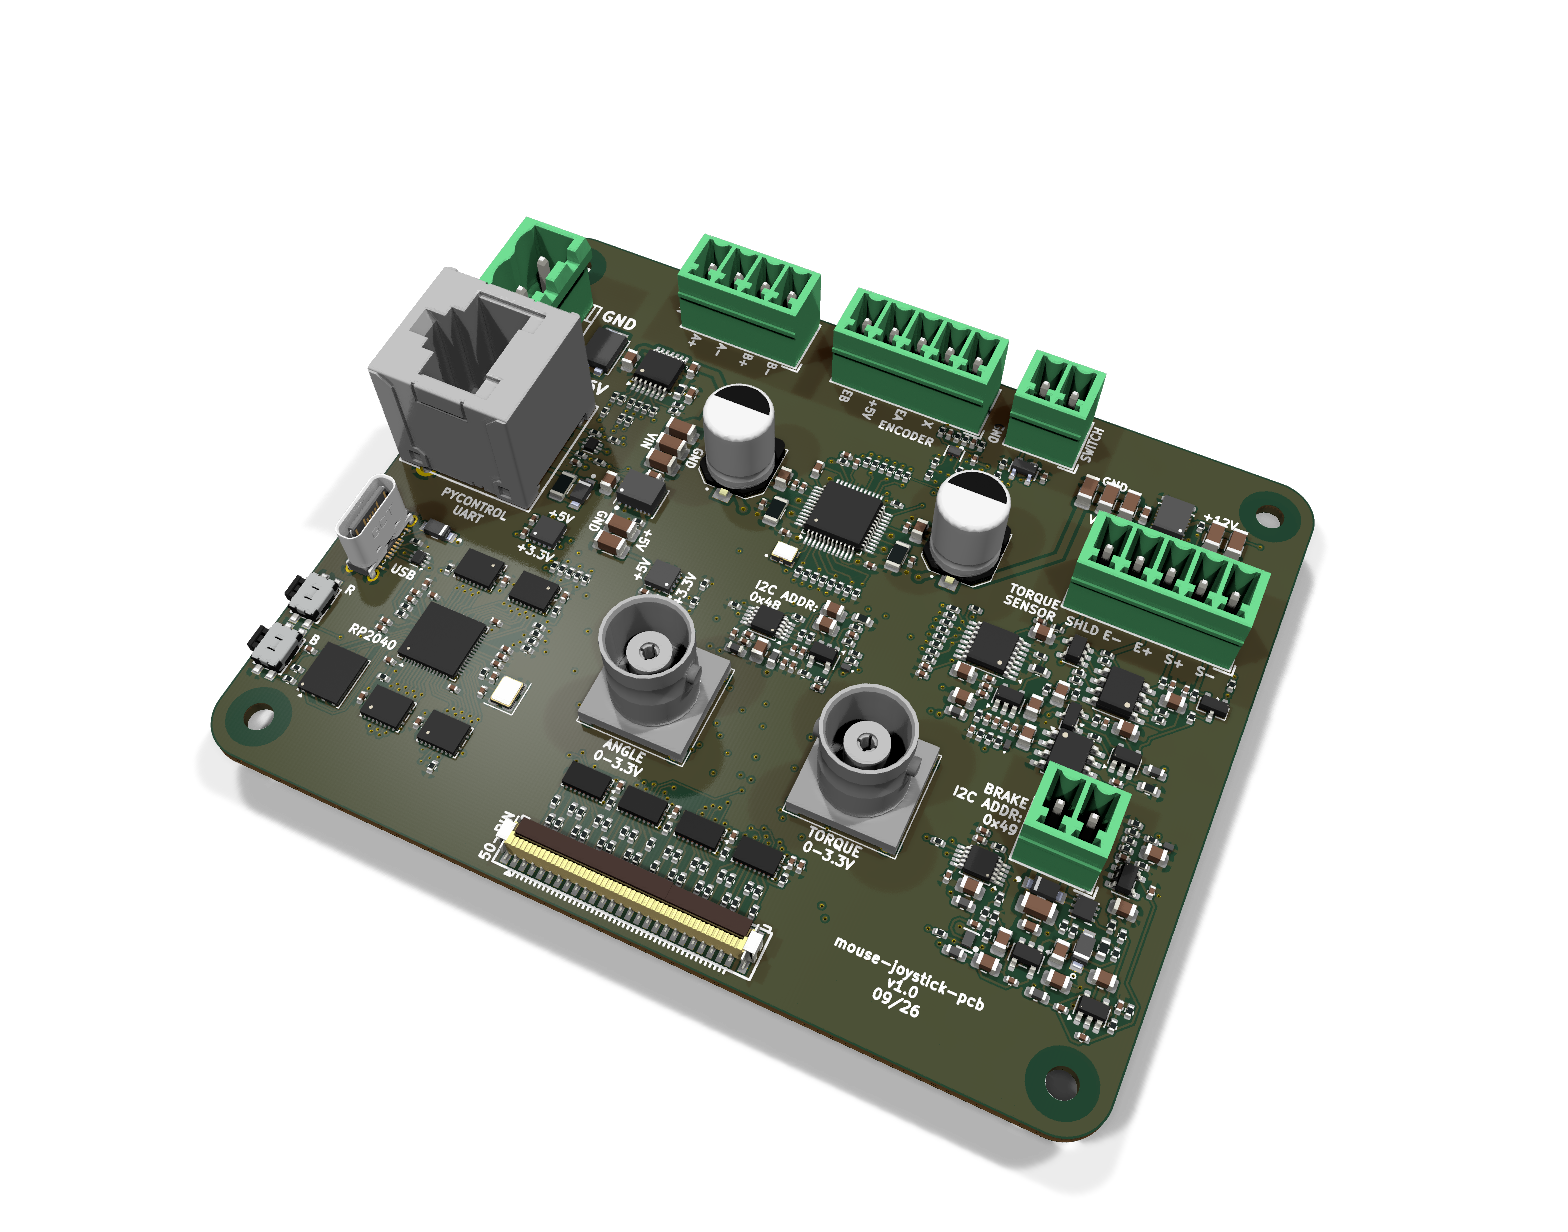
| Repository | mouse-joystick-pcb at v1.0 |
| Where it sits | one per station, under the mechanism in the placement study |
| Start with | README, interface map |
| Generated documentation | schematic, renders, BOM, geometry |
| Fabrication | the package the boards were ordered from |

Also: the UART protocol pyControl speaks to it, the
harness pinouts, power,
and the bring-up log with every measurement by board serial.
The firmware is mouse-joystick-firm (v1.0.0); its
architecture page and
circuit-to-code map say which code drives which circuit.
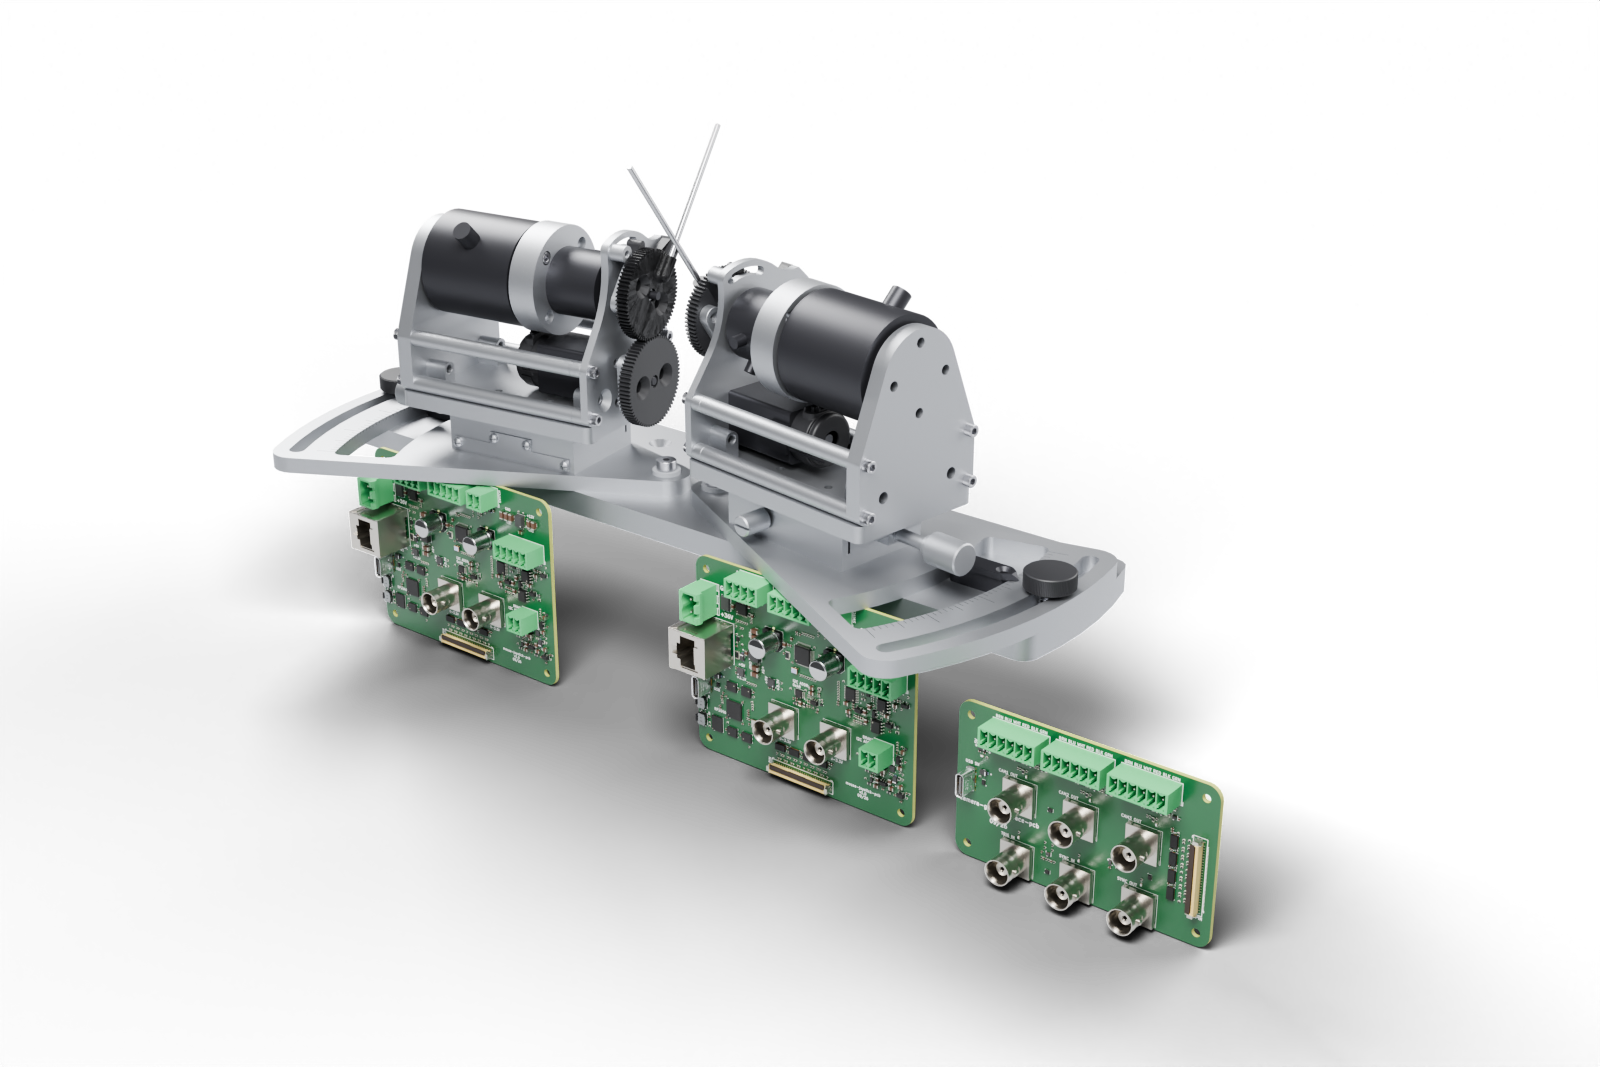
The boards in the placement study stand under their stations, terminal blocks up; where they finally mount is an enclosure decision. The camera interface board stands in their row beyond the end of the base plate only so that one picture shows every board of Rig 1; on the rig it sits by the cameras.
Camera GPIO interface board
Between pyControl and the three Blackfly S cameras; strobes and sync to the OneBox. Rig 1 only.

| Repository | camera-gpio-interface-pcb at v1.0 |
| Where it sits | one per rig, between pyControl and the cameras (Rig 1 only) |
| Start with | README, interface map |
| Generated documentation | schematic, renders, BOM, geometry |
| Fabrication | the package the boards were ordered from |